

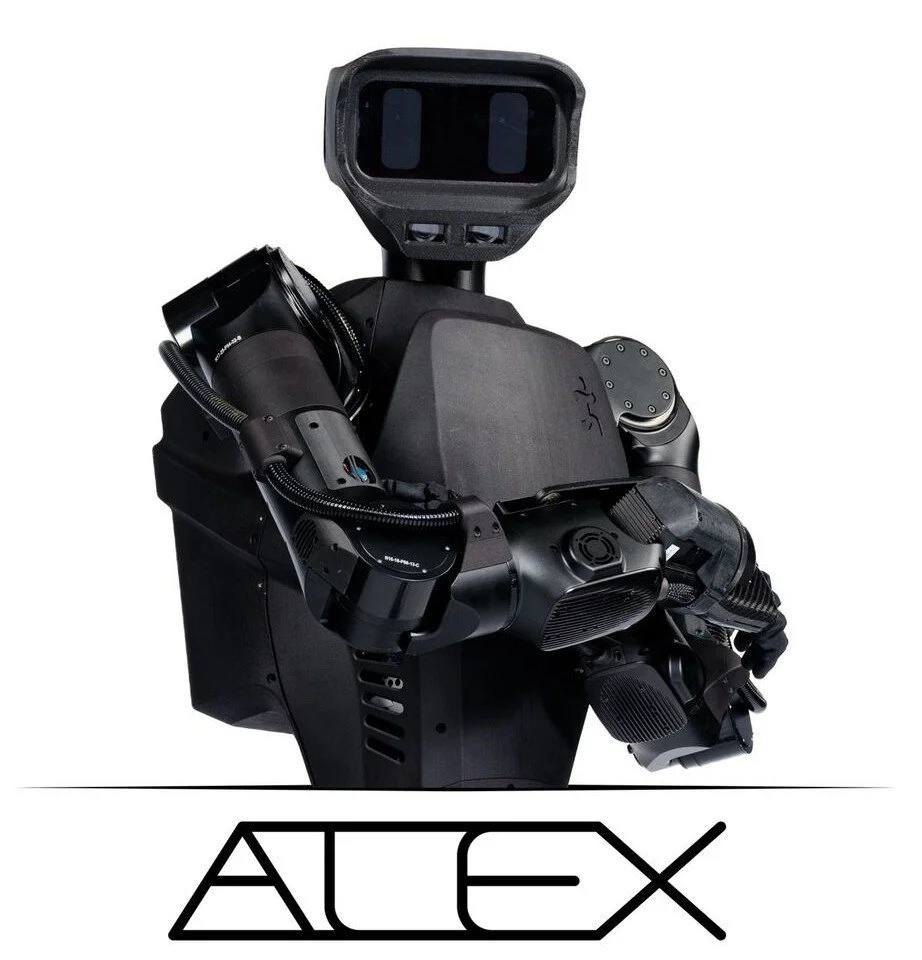
Alex is a general-purpose humanoid developed in collaboration with IHMC and Boardwalk Robotics.
Many robots use actuators with high (50:1 or higher) gear ratios. These enable the use of smaller motors, but require torque sensors which are expensive and difficult to make. Others use Quasi Direct-Drive with low (e.g. 6:1) gear ratios. These are backdriveable and responsive, but require large diameter, heavy motors.
All the actuators in Alex use custom cycloidal transmissions which I designed. The gear ratio is selected to allow open-loop torque control without a dedicated sensor, while still achieving high torques without a large heavy motor. The low-ish gear ratio means the robot is fast and responsive.
The actuators are backdriveable. This means they can swing freely, enabling the robot to utilize the system’s natural dynamics to save energy, just like animals do. This has the potential to greatly increase motion efficiency in humanoid robots.
Unlike traditional planetary or cycloidal gears, our custom transmission design means we can achieve very low backlash without excessive friction. They are also extremely efficient (around 96%) – great news for battery life on mobile robots.
Alex started out as a pair of arms for the Nadia robot. I came up with the idea of making these arms, and was lucky enough to be given the freedom (and funding) by IHMC and Boardwalk to make them happen. I did the mechanical design of the entire arm including three sizes of actuator, each with its own custom transmission. Electrical design was done by Alexis at H4 Lab.
The arms worked well, and IHMC decided to use these actuators as the basis for the entire humanoid. I designed all the actuators in the humanoid, as well as the pelvis and some of the hip structures.
Images and video courtesy of IHMC and Boardwalk Robotics